
Access is the moat.
The highest value work happens behind badge readers and NDAs. We are already inside, under exclusive agreements.

The data infrastructure layer for Physical AI.

Learn from how real work happens.
Study success, failure, and recovery.
Connect operations to their evidence.
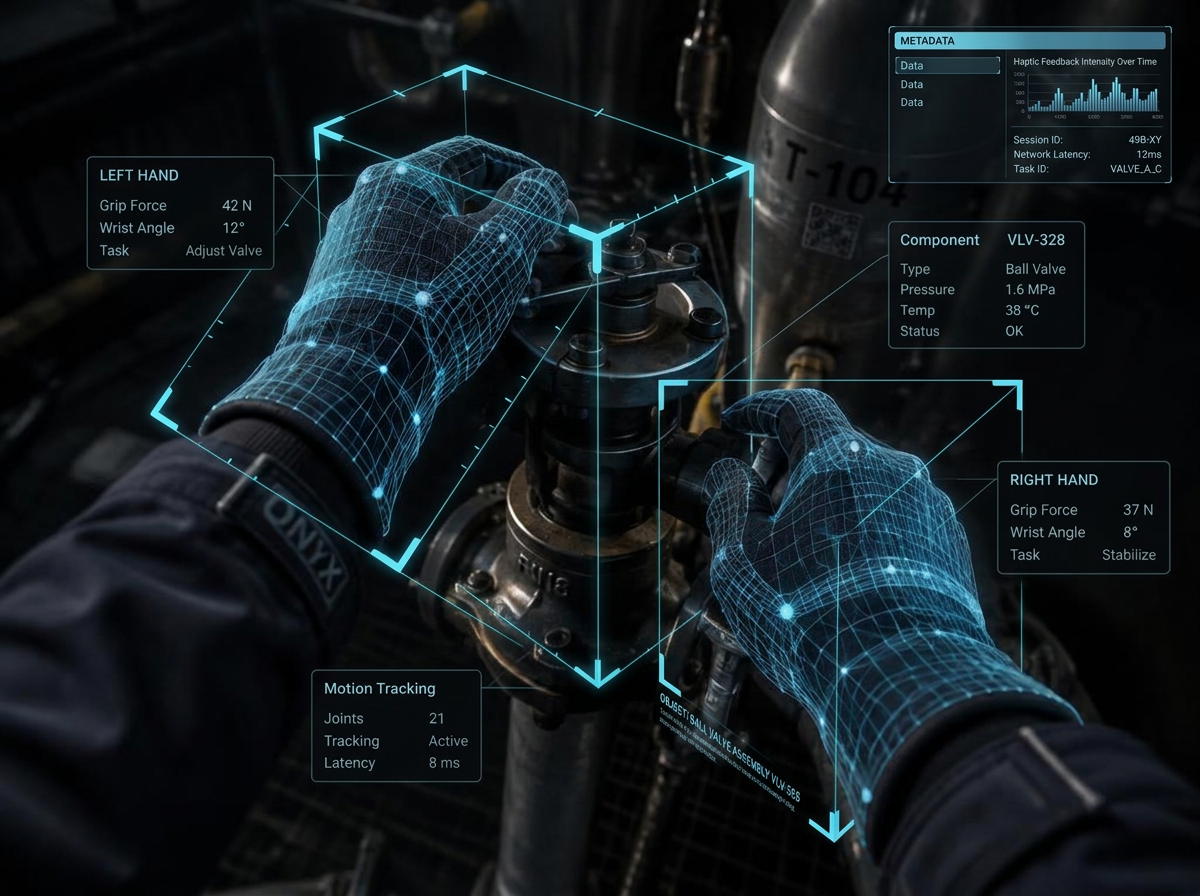
Real private industry. Closed doors. Alongside the operational experts that make the world turn.
Dataset is the data infrastructure layer for Physical AI, capturing authentic industrial work through exclusive agreements inside warehouses, plants, and service fleets. We deliver rights-cleared, operational-ready training data to robotics teams and AI labs.
We turn real-world operations into structured data and intelligence that AI developers and businesses can use.
The highest value work happens behind badge readers and NDAs. We are already inside, under exclusive agreements.
Vision, sensors, machine state and outcomes arrive together, time-synced, ready to train on.
Consent, rights and provenance ship with every episode, so your legal team clears it in days, not quarters.
Capture hardware, data processing, model training, and APIs. One connected system.
Access structured, training-ready episodes or commission proprietary capture of the tasks, environments, and failure modes your model has yet to master.
Go beyond footage. Structured, time-aligned episodes connect real-world actions, operational context, and observed outcomes, built to help your model learn what happened, where, and what came next.
First-person video and depth captured from the worker's own point of view, so the model sees the task exactly as the person performing it does.
Body and hand pose tracked over time, turning a movement into a measurable trajectory a policy can imitate.
Live readings from the equipment itself: controller signals, loads, speeds and alarms, time-synced to what the human is doing.
What the task was, where it happened, which objects were involved and what changed around it. Context that makes an action interpretable.
Whether the attempt worked, how it failed, and how it was recovered. Failure and correction are labeled, not discarded.
Consent, usage rights and a traceable chain of custody shipped with every episode, so legal clearance takes days instead of quarters.
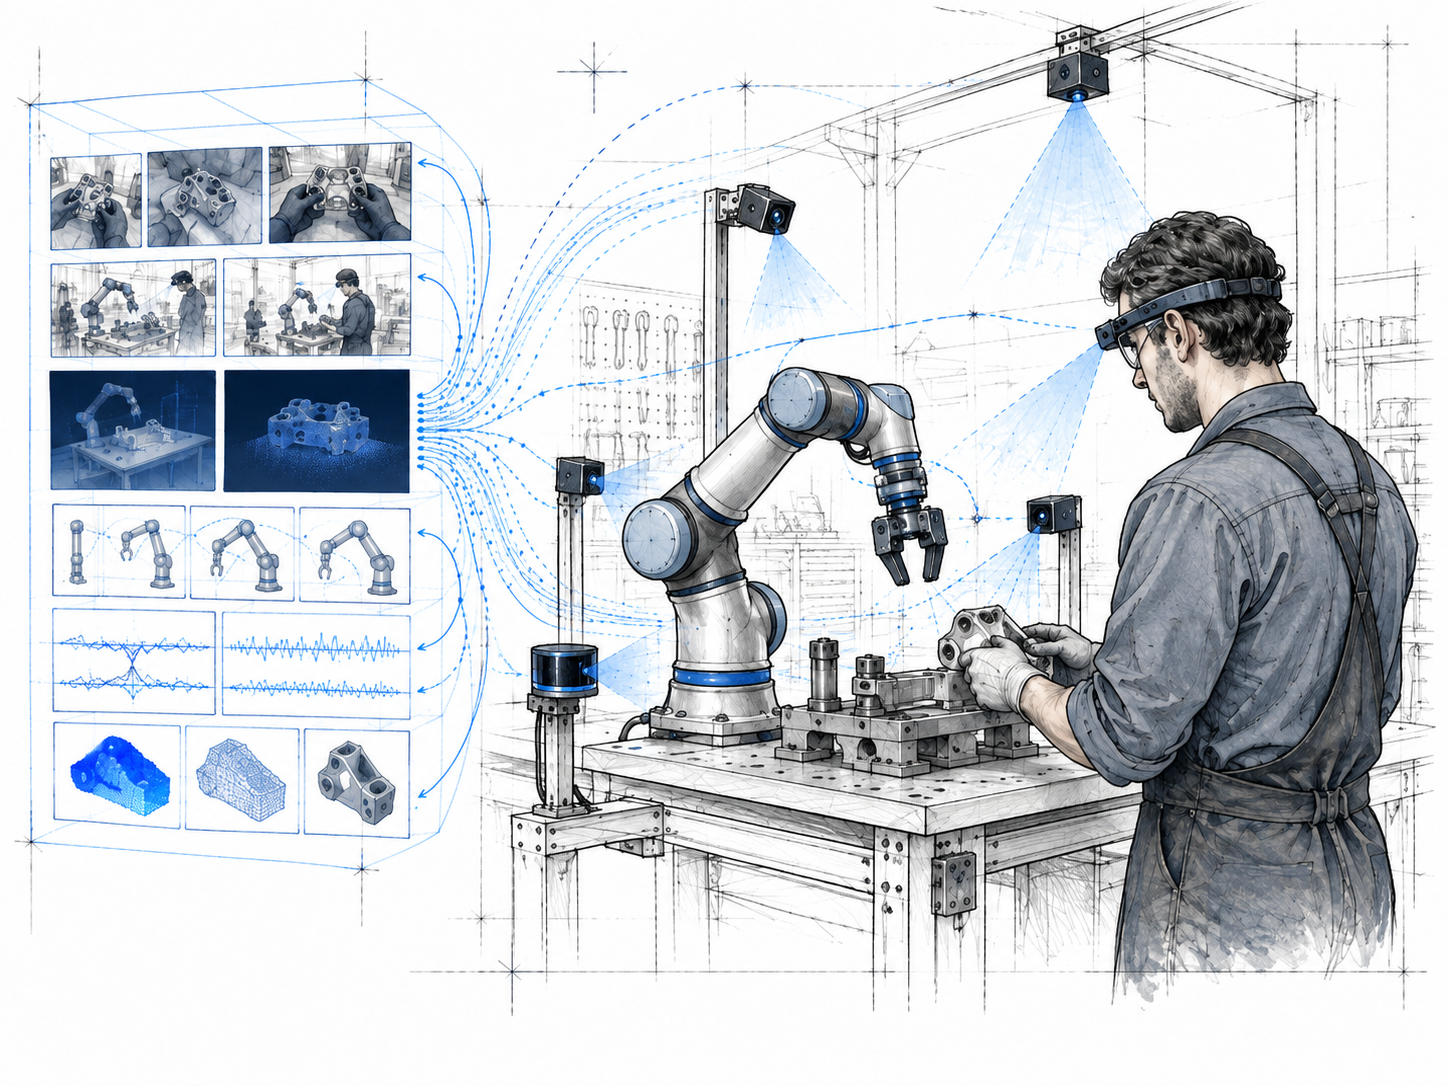
We are exploring models grounded in the states, actions, failures, recoveries and outcomes of real work.
Controlled research programSample episodes, pricing and site coverage for robotics and frontier AI teams. Exclusivity windows available per task category.
Request a sample →